1. Electronics Tools
  2. Drone & Multirotor Calculator

Drone & Multirotor Calculator

Enter your quad's weight, motors and battery: see if it flies well, how long it stays up, and whether the battery and ESCs can take the current.

Frames

All-up weight

Motors
Total, ready to fly1174 g

A F450 quad frame is meant for up to 2000 g.

Motors and props

A 1045 prop is 10″ × 4.5″ pitch; a 5043 is 5″ × 4.3″.

Battery and ESC

Cells

How you fly

Steady forward flight a little above hover throttle: mapping, long range.

Your craft

≈ 14 minThrust ⁦3400 g · 2.9:1⁩Weight ⁦1174 g⁩

Hovering at about 49 % throttle. Solid green: the thrust it takes to hover; dashed: what full throttle gives. Blue and orange props spin in opposite directions.

Thrust-to-weight

2.9: 1

Good

Stable with enough reserve to climb and fight wind: right for camera and cruising.

4 × 850 g = 3400 g of thrust for 1174 g.

Full-throttle current vs battery (5200 mAh × 35C)62 A / 182 A
Current per motor vs ESC rating15.4 A / 30 A

An ESC of 20 A or more per motor leaves a 20 % margin.

Results

Hover throttle
49 %
Hover time
19 min
Flight time (Cruise)
14 min
Hover current
12.9 A
Prop speed under load
7 659 rpm
Prop tip speed
102 m/s · M0.3

Balanced build: enough thrust, the battery and ESCs can take the current.

Battery suggestion

Same cell count, half to double the capacity: the lightest pack that gets close to the longest flight without losing the punch your flying style needs.

3S 8000 mAh · ≥ 10C

About 18 min at 2.4:1 (pack ≈ 631 g).

Step by step

  1. W

    AUW = frame + n × motor + battery + electronics + payload

    = 280 + 4 × 56 + 410 + 110 + 150 = 1174 g

  2. T/W

    T/W = n × T ÷ AUW

    = 4 × 850 g ÷ 1174 g = 2.9

  3. %

    hover throttle = (AUW/n ÷ T)^(2/3)

    = (294 g ÷ 850 g)^(2/3) = 49 %

  4. P

    P = T^1.5 ÷ √(2ρA) ÷ η, I = (n × P + avionics) ÷ V

    = A = 0.0507 m², η = 40 % → (4 × 34.6 W + 5 W) ÷ 11.1 V = 12.9 A

  5. t

    t = 80 % × C ÷ I

    = 4160 mAh ÷ 12.9 A = 19 min (⁨your style⁩: ÷ 17.3 A = 14 min)

  6. I

    Imax = n × Pmax ÷ V ≤ C × Ah

    = 4 × 171 W ÷ 11.1 V ≈ 62 A ≤ 35C × 5.2 Ah = 182 A

  7. rpm

    rpm = KV × V × 0.75, tip = π × D × rpm ÷ 60

    = 920 × 11.1 V × 0.75 = 7659 rpm → 102 m/s (Mach 0.3)

Good to know

Bigger, slower props

A large prop turning slowly lifts more per watt than a small fast one. That's why camera drones use 10″ props and low-KV motors.

Every gram counts

Power grows faster than weight (weight^1.5). Cutting 10 % of the weight gives about 15 % more flight time.

Land at 3.5 V per cell

Using only 80 % of a LiPo keeps it healthy. Store packs at 3.8 V per cell, never full or empty.

Props off on the bench

Check motor direction and the failsafe without props. Spinning props cut deep: fit them only at the field.

How the estimate works

Thrust-to-weight is total full-throttle thrust ÷ weight. To hover, each motor makes weight ÷ motors; thrust grows roughly with throttle^1.5, which gives the hover throttle. The power a prop needs comes from momentum theory: P = T^1.5 ÷ √(2ρA), divided by an efficiency of 26–40 % (bigger props are more efficient). Current is power ÷ battery voltage, and flight time is 80 % of the capacity ÷ that current. Real flights vary by about 20 %: wind, temperature and battery health count.

How to size a drone's motors, battery and ESCs

How the drone calculator works

T/W = motors × thrust per motor / all-up weight

Everything starts from the all-up weight: frame, motors, battery, electronics and any payload, ready to fly. Divide the total full-throttle thrust by it to get the thrust-to-weight ratio. Below 2:1 a drone feels sluggish; camera drones fly well around 2.5–4:1 and FPV quads often exceed 8:1.

To hover, each motor only has to carry its share of the weight. Thrust grows roughly with throttle to the power 1.5, so the hover throttle is (weight per motor ÷ max thrust)^(2/3). The power a propeller needs to make that thrust follows momentum theory, P = T^1.5 / √(2ρA), divided by a real-world efficiency of 26–40% depending on prop size.

The current is that power divided by the battery voltage (3.7 V per cell). Flight time is the usable capacity (80% of the label, to keep the LiPo healthy) divided by the average current. The full-throttle current is checked against the battery's C rating and each motor's current against the ESC.

Worked example: an F450 quad on 3S 5200 mAh

An F450 weighs 1 174 g ready to fly with four 2212 920KV motors that each make 850 g on 1045 props, a 3S 5200 mAh 35C pack and 30 A ESCs.

  1. Thrust-to-weight4 × 850 g / 1174 g = 2.9 : 1
  2. Hover throttle(293.5 g / 850 g)^(2/3) ≈ 49%
  3. Hover current(4 × 34.6 W + 5 W) / 11.1 V ≈ 12.9 A
  4. Hover time5200 mAh × 0.8 / 12.9 A ≈ 19 min
  5. Full-throttle current≈ 62 A ≤ 35C × 5.2 Ah = 182 A

A good 2.9:1 camera drone: about 19 minutes hovering and 14 minutes cruising. Each motor pulls up to about 15 A, so the 30 A ESCs have plenty of margin and a 20 A ESC would also do.

Common mistakes

  • Forgetting the battery in the weight

    The battery is often a third of the all-up weight. Weigh the drone ready to fly, with the pack, camera and straps.

  • Draining the LiPo to zero

    Flight time uses 80% of the capacity. Flying a LiPo below 3.5 V per cell under load swells and kills it within a few cycles.

  • Thinking a bigger battery always flies longer

    A bigger pack adds weight, and the extra weight raises the hover current. Past a point the flight barely gets longer while the drone loses its punch.

  • Trusting the C rating blindly

    Many packs can't really deliver their printed C rating. Keep a margin: if full throttle needs 150 A, a 1500 mAh 100C pack is the minimum, not a comfortable choice.

Drone calculator FAQ

At least 2:1 to fly safely. Camera and mapping drones are comfortable at 2.5–4:1, freestyle FPV quads at 6–10:1 and racing quads go higher. Below about 1.2:1 a drone can barely take off.

Divide the usable capacity by the average current: 5200 mAh × 0.8 / 13 A ≈ 19 min. The average current depends on the weight, the props and how hard you fly, which is what this calculator estimates.

The maximum current divided by the capacity in amp-hours, plus a margin: 62 A / 5.2 Ah ≈ 12C, so any 3S 5200 pack of 20C or more is fine. FPV quads pull far more, often 150 A from a 1500 mAh pack.

Each ESC must handle the current of one motor at full throttle, with about 20% margin. Read it in the motor's thrust table or use the calculator's estimate.

KV is the speed the motor turns per volt without load: a 920KV motor on 11.1 V spins about 10 200 rpm free, around 7 650 rpm with a prop. Low-KV motors swing big props; high-KV motors spin small ones.
Free shipping

On orders over 5000DA

Easy returns

7-day hassle-free returns

Fast checkout

payments on delivery and fast shipping

24/7 support

We're here to help

Dzduino Online Store

Eempowering engineers, students, makers, researchers, and businesses with high-quality and innovative technical solutions.

  • Sales: store@dzduino.com
  • Store: +213 550 88 88 27
  • Sales: +213 550 88 88 29
  • Support: +213 550 88 88 37
  • 043 Cite Remila (Route du Port), Tigditt - Mostaganem

Shop

  • All Categories
  • Électronique & Développement
  • Tools & Equipements & DIY
  • Téléphonie & Communication
  • Fabrication & Prototyping
  • Computers & Networks
  • Power & Energy & Solar
  • Video Surveillance & Security systems
  • Educational, Scientific and Laboratory

Support

  • Track order
  • Orders
  • Account
  • Shipping & returns
  • Shipping calculator

Company

  • About
  • Contact us
  • Site map
  • Privacy
  • Terms

Stay in the loop

New stock, maker deals, and electronics tips — straight to your inbox.

© 2026 Dzduino Electronics, All Rights Reserved

TermsPrivacyShipping & returnsSite map
CIBBARIDI MobFawriPayCash
Free express shipping on orders over 10,000DA
SpecialSaleBlogPrint & CutLabContact usToolsNewLabNew

Related products

Boards, modules, and kits that pair with this tool.

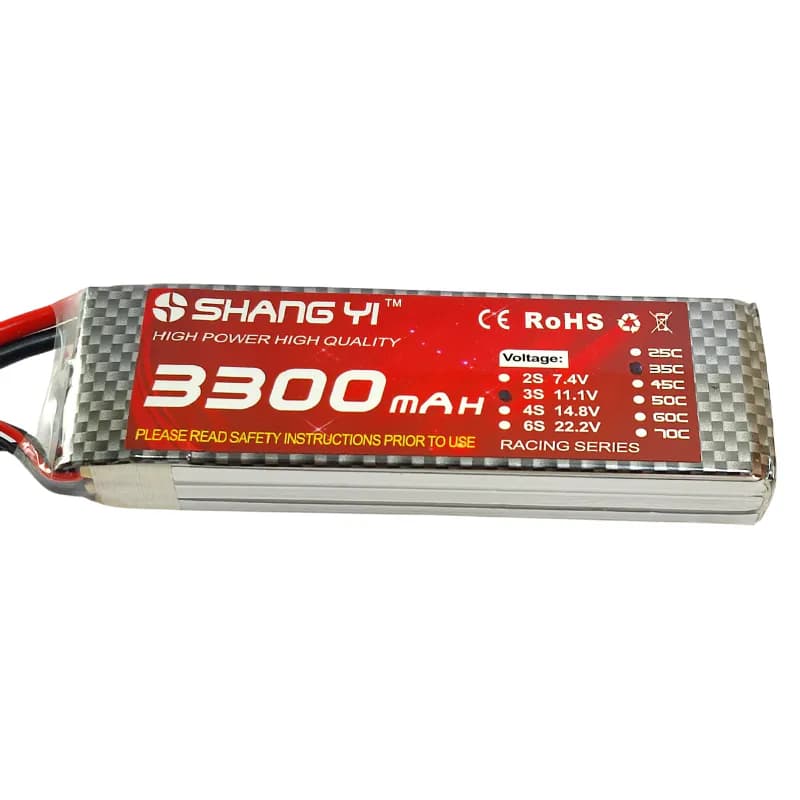
11.1V 3S 3300mah/35C Lipo Battery with XT60
DZD0002100

11.1V 3S 3300mah/35C Lipo Battery with XT60

DZD 9,500.00Out of StockOut of Stock
iMAX B6 Digital RC Lipo NiMH/ battery Balance Charger
DZD0002120

iMAX B6 Digital RC Lipo NiMH/ battery Balance Charger

DZD 7,500.00Out of StockOut of Stock
11.1V 3S 5200mah/35C Lipo Battery with XT60
DZD0003830

11.1V 3S 5200mah/35C Lipo Battery with XT60

DZD 13,200.00Out of StockOut of Stock
XXD HW30A 30A Brushless Motor ESC
DZD0003850

XXD HW30A 30A Brushless Motor ESC

DZD 2,200.00Out of StockOut of Stock
40A Brushless ESC Electronic Controller BEC 5V/ 3A
DZD00038611

40A Brushless ESC Electronic Controller BEC 5V/ 3A

DZD 2,900.00In StockIn Stock
XXD A2212 1000KV Brushless Motor
DZD0009140

XXD A2212 1000KV Brushless Motor

DZD 2,800.00Out of StockOut of Stock
3.7v 3000mah Rechargeable  Lipo Battery
DZD0014990

3.7v 3000mah Rechargeable Lipo Battery

DZD 650.00Out of StockOut of Stock
Brushless Motor KV1400
DZD0016620

Brushless Motor KV1400

DZD 2,400.00Out of StockOut of Stock
View all